Underactuated Metamorphic Palm Simulation
Modeling a closed-loop, five-link palm for a three-fingered hand in Isaac Sim and Webots, with loop-closure constraints, mesh optimization, and reconfiguration stability analysis.
I built Isaac Sim and Webots environments for an underactuated metamorphic palm with a closed-loop five-link mechanism for a three-fingered hand. My work focused on modeling loop-closure constraints, simplifying meshes to enable simulation on an 8 GB GPU, and investigating instability during palm reconfiguration in preparation for preliminary reinforcement learning experiments.
Simulation Demos
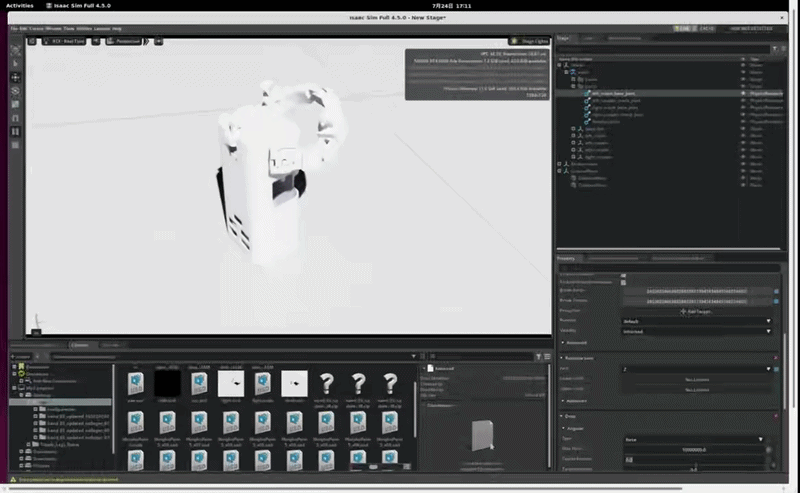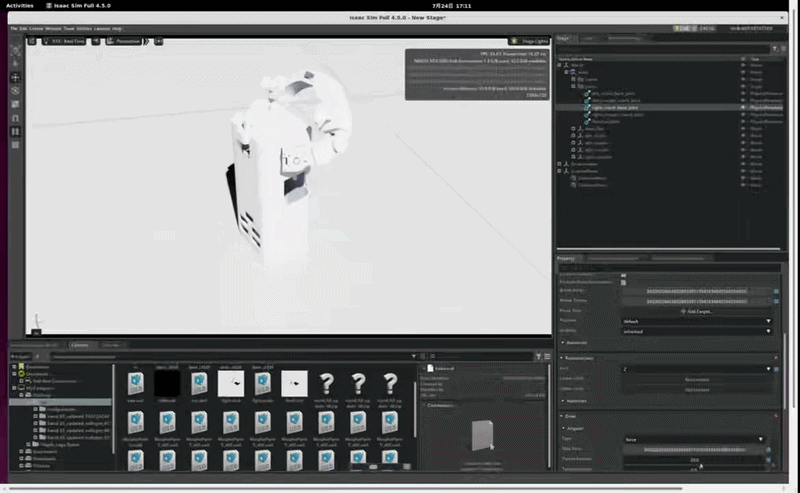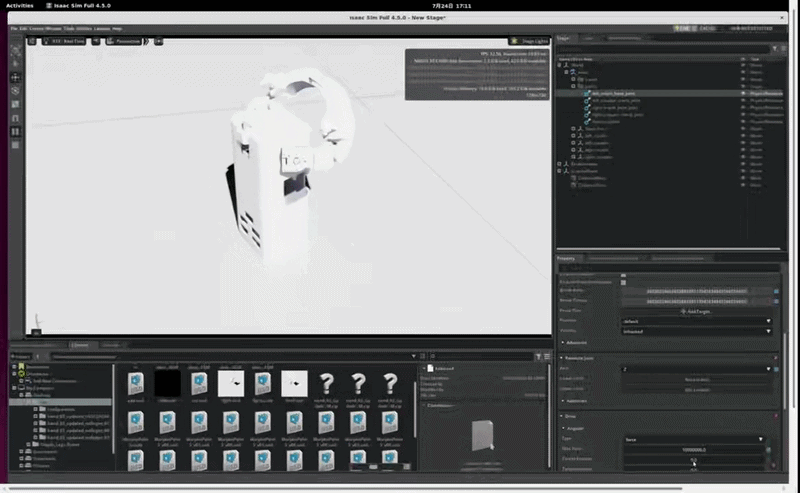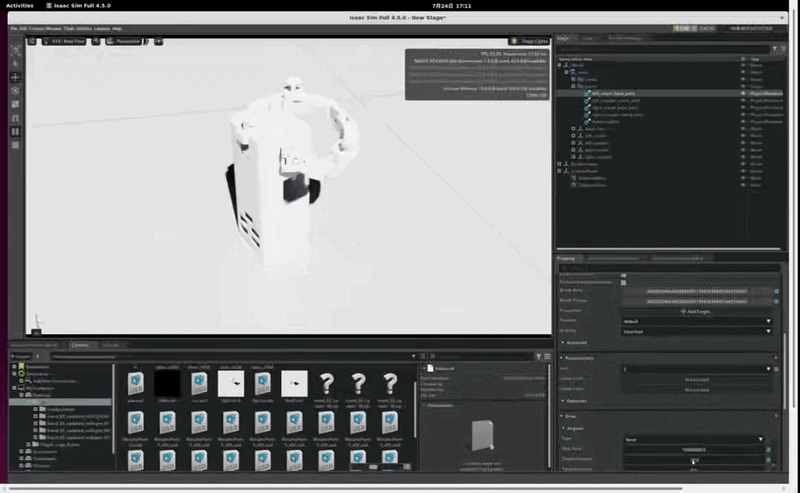
Simulation of the metamorphic palm's closed-loop mechanism in NVIDIA Isaac Sim.
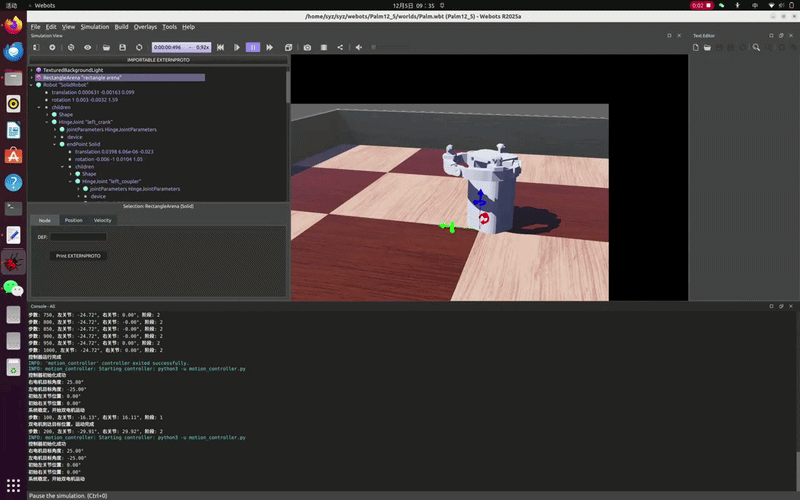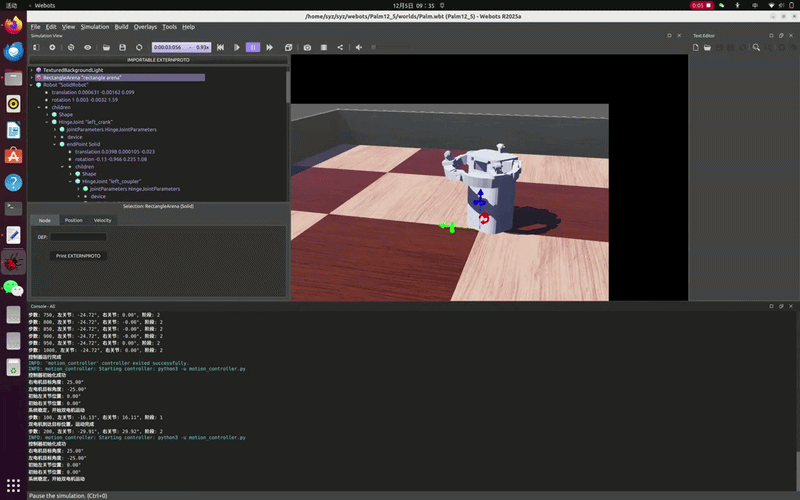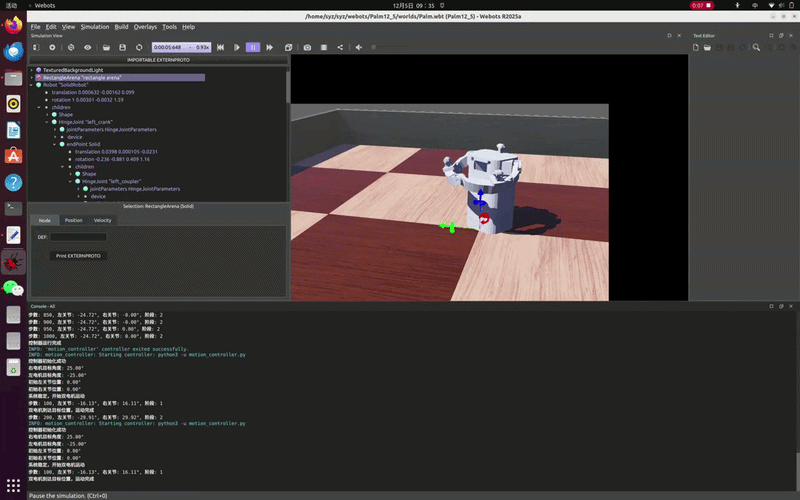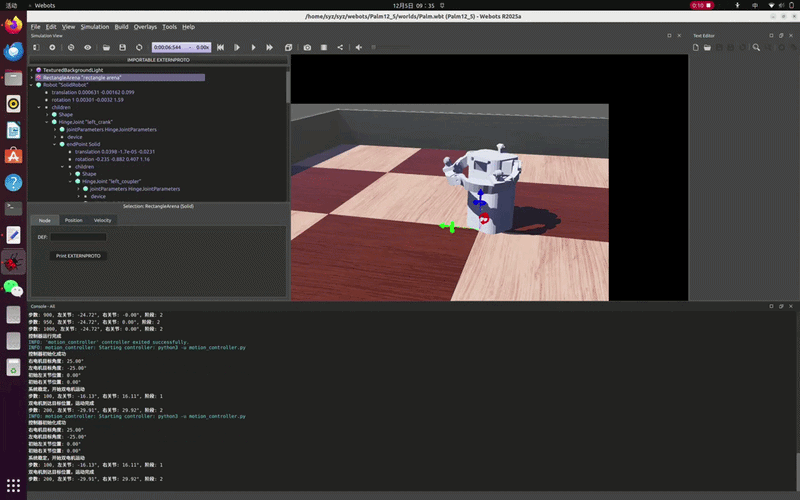
Simulation of the metamorphic palm's closed-loop mechanism in Webots.
Work Done
- Closed-Loop Modeling: Added loop-closure constraints to the URDF models and built Isaac Sim and Webots environments for preliminary reinforcement learning experiments.
- Mesh Optimization: Simplified meshes while preserving geometry at contact regions, resolving GPU memory failures and enabling simulation on an 8 GB GPU.
- Reconfiguration Stability: Analyzed joint constraints and tuned damping, stiffness, and friction to investigate instability during palm reconfiguration and identify limitations in simulation fidelity.